
About me
My name is Zhenyu Wu (吴镇宇). I am a Ph.D. student in Computer Science and Technology at the College of Electronic and Information Engineering, Southwest University, supervised by Prof. Chuandong Li. I received my master’s degree in Control Science and Engineering from Guangdong University of Technology in 2023.
My research connects mmWave radar signal processing, robotic perception and state estimation. Building on my background in multi-agent control and filtering, I develop sensing methods and experimental platforms that connect radar measurements with robotic systems.
Research interests
- Radar sensing and super-resolution: coherent extension, range–angle estimation and point-cloud generation for frequency-modulated continuous-wave (FMCW) radar.
- Robotic perception and state estimation: target tracking, radar–inertial sensing and multimodal data collection.
- Information-driven control: active perception and motion decisions under sensing and field-of-view constraints — an ongoing research direction.
Selected research & projects
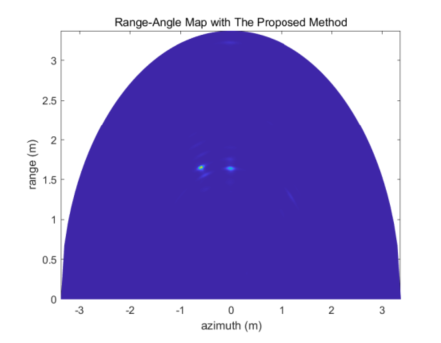
Super-resolution mmWave radar
Coherent extension and adaptive estimation for improved range and angle resolution, with real radar measurements.
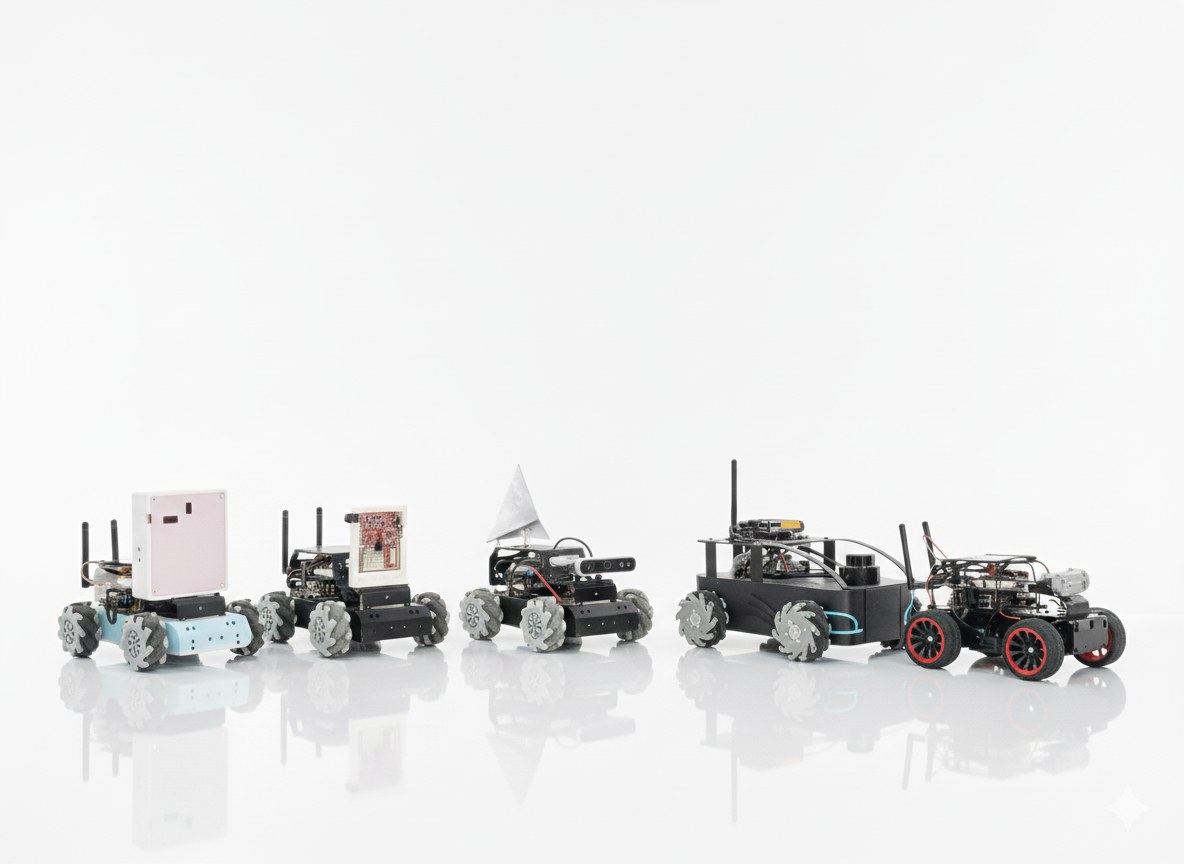
Radar-driven mobile robots
Self-built heterogeneous mobile robots for radar sensing, target following and multi-robot experiments.
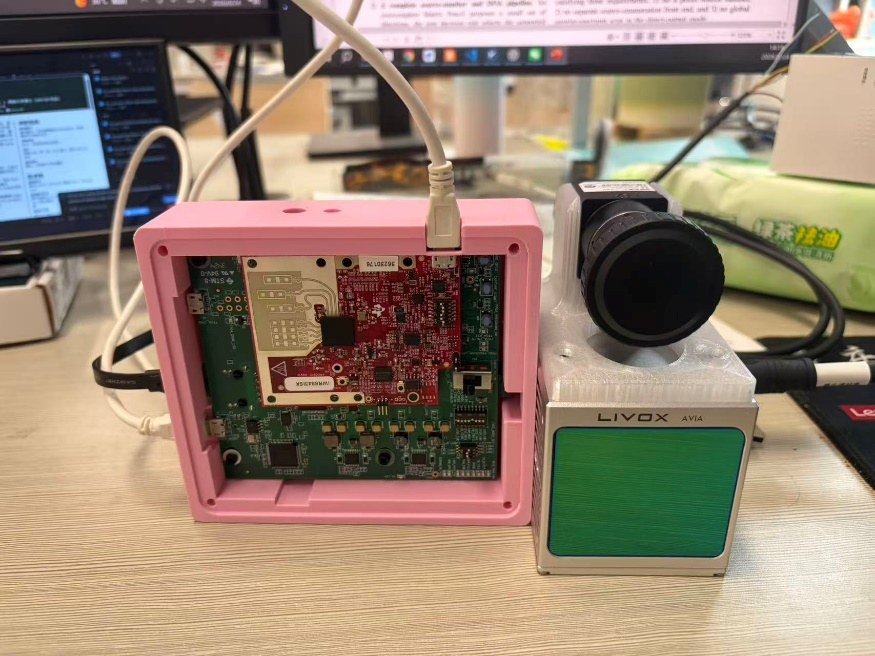
Multimodal sensing platform
Radar, LiDAR, camera and IMU integration with hardware synchronization and a repeatable acquisition workflow.
View all projects and experiments →
Selected publications
- Z. Wu, Y. Li, T. Hu, C. Li, and Z. Luo. “Resolution Enhancement for mmWave Radar With Matrix Pencil-Based Coherent Extension.” IEEE Transactions on Consumer Electronics, 71(1): 2350–2352, 2025. DOI
- Z. Wu, X. Ma, F. Chang, C. Li, Z. Luo, and M.-F. Leung. “Enhanced Sensing for Automotive mmWave Radar: Super-Resolution Range and Angle Estimation With Coherent Extension and Advanced IAA.” IEEE Transactions on Consumer Electronics, 71(2): 4797–4806, 2025. DOI
Open source
- ti-radar-cli: command-line tools for radar checks, configuration and raw ADC acquisition, designed for use in agent workflows.
- ti_mobile_tracker_ros2: a ROS 2 driver for TI Mobile Tracker point clouds and tracking data.
- codex-chatgpt-bridge: a bridge for ChatGPT–Codex collaboration and controlled local execution.
Contact
I welcome conversations about radar sensing, robotic perception and research collaboration. If you are interested in an implementation associated with my publications, please feel free to reach out at zheny_wu@163.com.