
Multimodal sensing platform
This platform brings together mmWave radar, LiDAR, a camera and an IMU for repeatable multimodal data collection. I worked on system integration, hardware synchronization and the acquisition workflow.
Handheld sensing rig
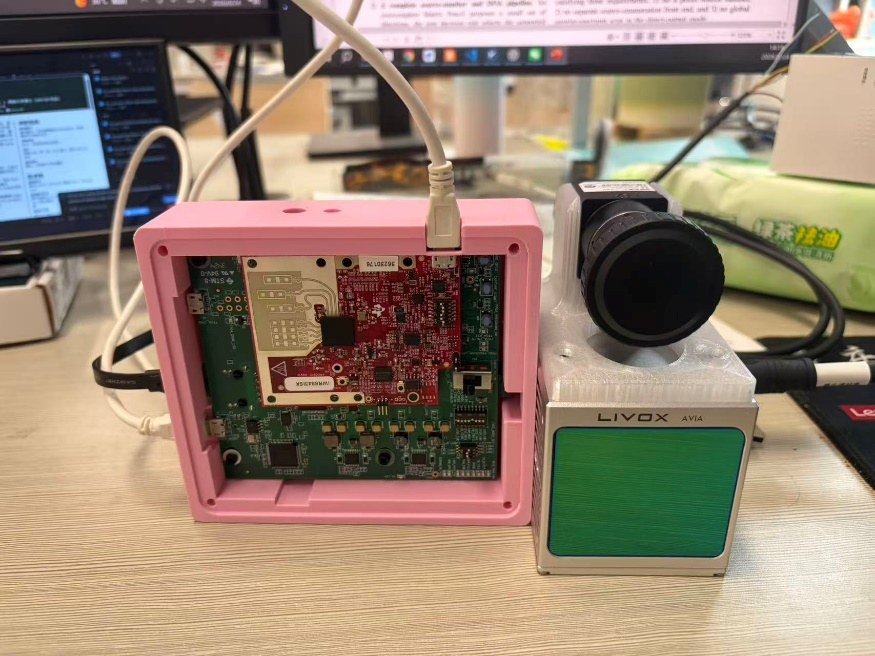
Sensors & acquisition
- Radar: TI AWR1843BOOST with DCA1000EVM for raw ADC capture.
- LiDAR: Livox Avia.
- Additional sensing: industrial camera and IMU.
- Synchronization: a self-built hardware synchronizer provides a common timing reference for timestamp alignment.
- Workflow: coordinated acquisition, extrinsic calibration, offline data checks and visualization.
Wearable collection configuration
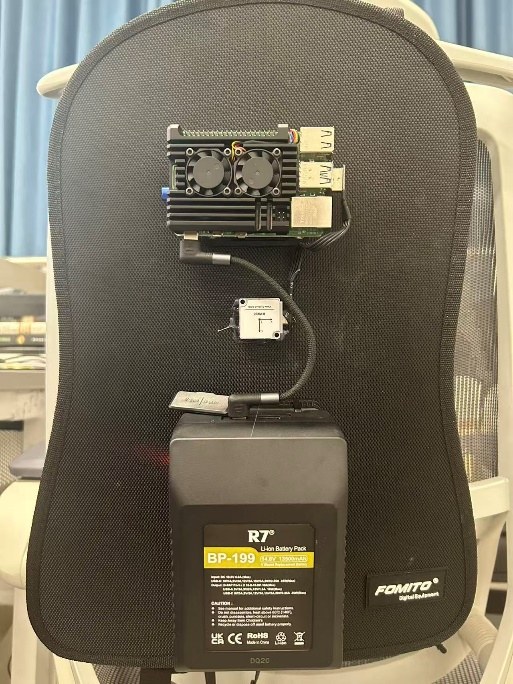
Research use
The platform provides a data-collection foundation for radar–inertial sensing and multi-sensor fusion experiments. The photographs document the system configuration; no synchronization-accuracy or localization benchmark is claimed here.
See also the mobile-robot platform and radar acquisition tools.