
Radar-driven mobile robots
I initiated and helped build a mobile-robot testbed to connect mmWave radar sensing, state estimation and motion control. The platform includes raw-data acquisition robots, radar evaluation-module robots and complementary sensing configurations.
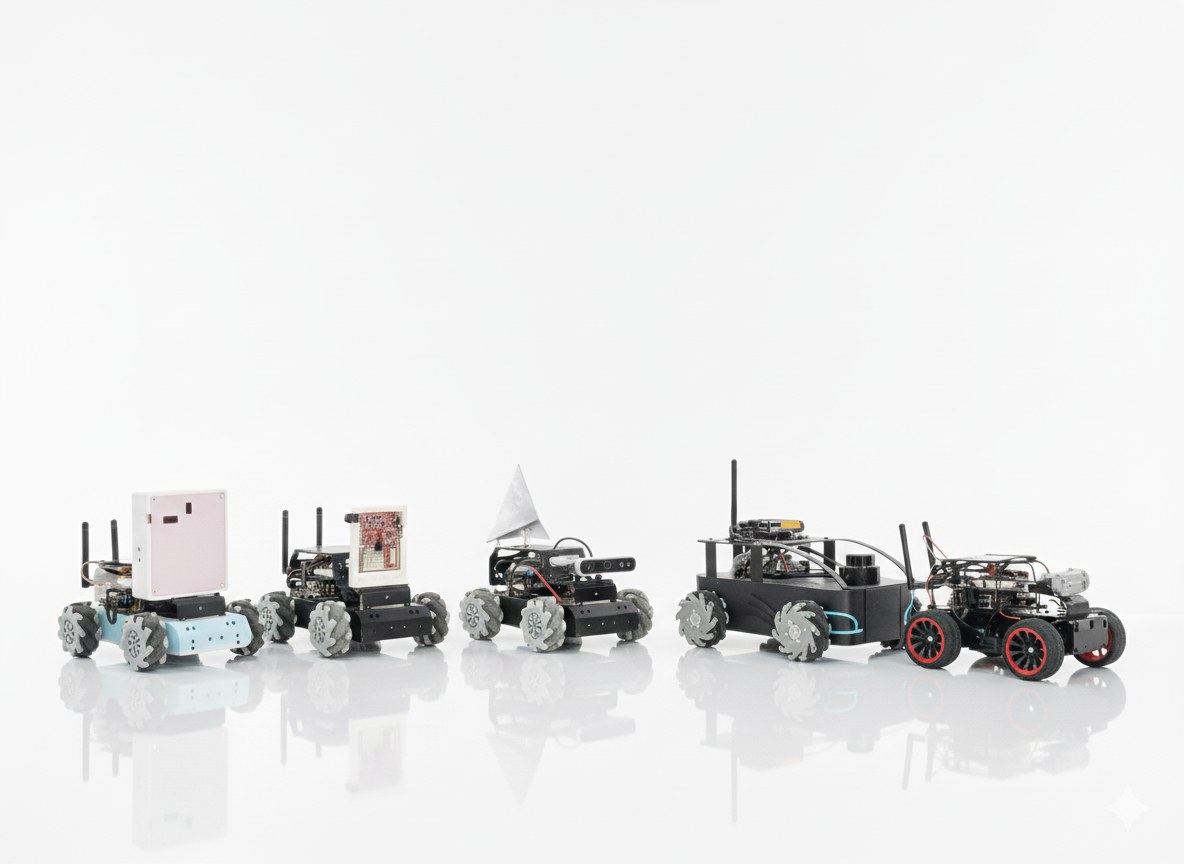
My role
- Initiated the project and coordinated a cross-group student team.
- Worked on platform selection and assembly, radar/computing integration, and visualization and debugging tools.
- Supported onboarding and weekly discussions to help students run experiments on the platforms.
Radar-based following
The following experiment uses relative radar measurements without an external positioning system. The clip below is extracted from the original research presentation.
Multi-robot experiments
The recordings show formation initialization and motion on the physical platforms. These demonstrations are presented separately from the ongoing research on information-driven motion planning.
Super-resolution point clouds
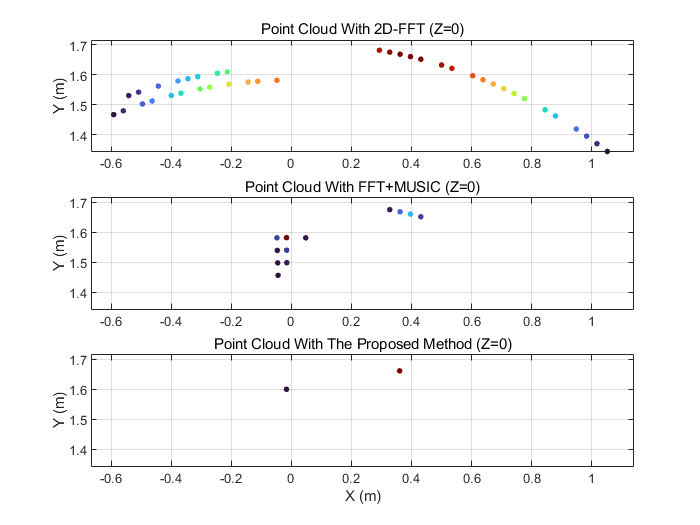
The comparison below comes from the point-cloud work presented at IEEE ISPCE-ASIA 2025. It compares conventional 2D-FFT, FFT + MUSIC and the proposed processing pipeline.
Related publication & software
- F. Wang, C. Wang, P. Gao, Z. Wu, X. Yang, and Y. Shi. “A Super-Resolution Point Cloud Generation Method for mmWave Radar.” IEEE ISPCE-ASIA, 2025, pp. 1–6. DOI
- ti_mobile_tracker_ros2: ROS 2 driver for TI Mobile Tracker point clouds and tracked targets.
- Radar super-resolution research.
The platform supports projects CYB25139 and YBXM202502006.